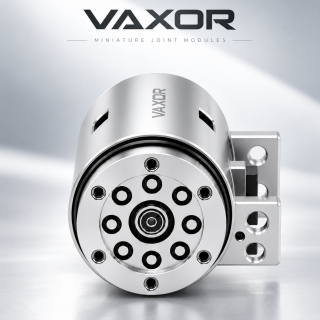


VAXOR: Robot Joint Actuator Manufacturer for Medical Robots
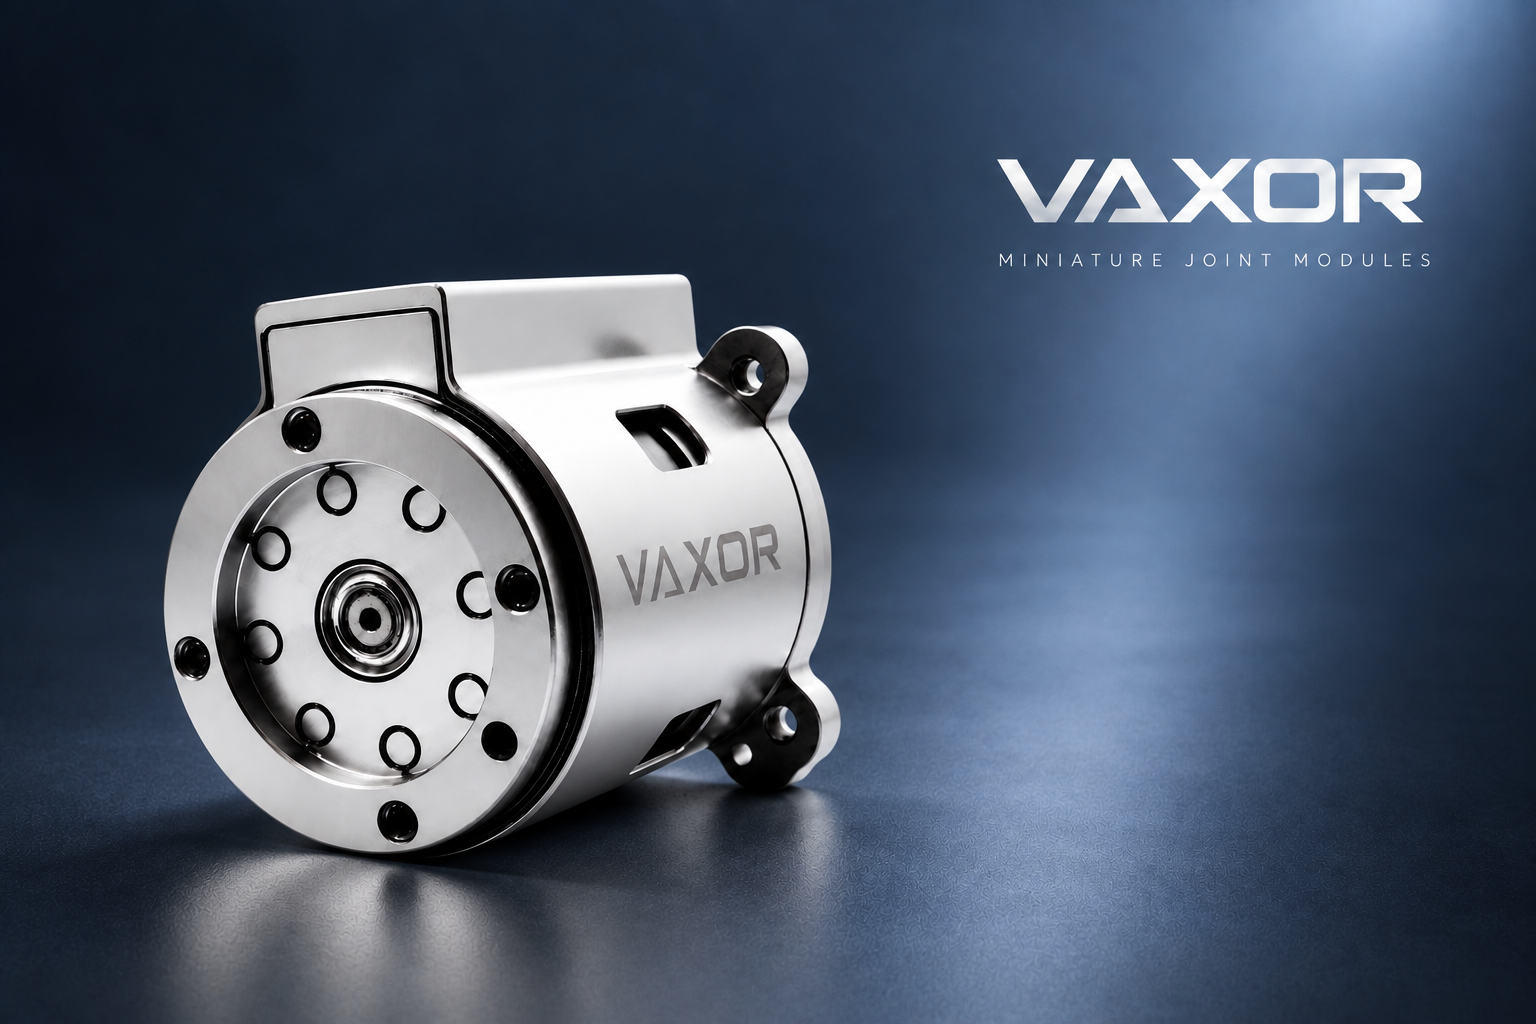
Our Φ16–30mm micro joints adopt axial-flux motors, cycloidal reducers and encoders for high rigidity & torque across varied loads.
The Precision Challenge in Medical Robotics
Medical robotics has created a specific engineering demand: actuation systems that combine high torque density, positional accuracy, and a compact footprint, all within devices that often operate in confined anatomical spaces or require extreme miniaturization. Micro-surgical tools, dexterous robotic hands used in clinical settings, and micro-pump systems for fluid transmission each depend on actuators and motors that must perform reliably without adding bulk or sacrificing control precision. This is the specific problem space that VAXOR-MOTOR, operating under the brand VAXOR, is built to address.
VAXOR-MOTOR’s Positioning in Micro-Actuation
VAXOR-MOTOR is positioned as a provider of integrated micro-actuation solutions, with a technology platform built around three core components: axial flux motors, micro cycloidal gear reducers, and non-contact absolute magnetic encoders. Rather than treating these as separate parts, VAXOR-MOTOR integrates them into unified modules, a design choice intended to achieve high torque density and rigidity while keeping unit size and weight low.
A defining technical characteristic of this platform is electromagnetic design optimized to keep phase imbalance within 5% for ultra-micro motors. Phase imbalance directly affects manufacturing yield and long-term reliability, so controlling it within this range is a core part of how VAXOR-MOTOR approaches both cost efficiency and consistency across production runs.
Core Technology: Axial Flux Motors, Cycloidal Reducers, and Magnetic Encoding
The technical foundation of VAXOR-MOTOR’s product line rests on modular design architecture and optimized electromagnetic design for both brushless and coreless motor systems. Within this architecture:
Actuator diameters range from Φ16mm to Φ30mm, covering a spread of load and integration requirements.
Gear efficiency reaches up to 75% in specific modules, which matters directly for systems where power consumption and heat generation must be tightly managed, such as wearable or handheld medical instruments.
Backlash is controlled as low as 15–20 Arcmin, a metric that speaks directly to positional accuracy in repetitive or fine-motion tasks.
Non-contact absolute magnetic encoders are integrated into the modules to provide precise position feedback, which supports high-precision motion control without introducing the wear concerns associated with contact-based sensing.
Product Lineup Relevant to Medical and Precision Robotics
VAXOR-MOTOR’s product matrix is organized around two main lines: Micro Joint Actuator Modules and Ultra-Micro Brushless & Coreless Motors.
Micro Joint Actuator Modules
This line is positioned for precision actuation in dexterous robotic hands, highly integrated robots, and mechanical motion control, applications with direct relevance to medical device development.
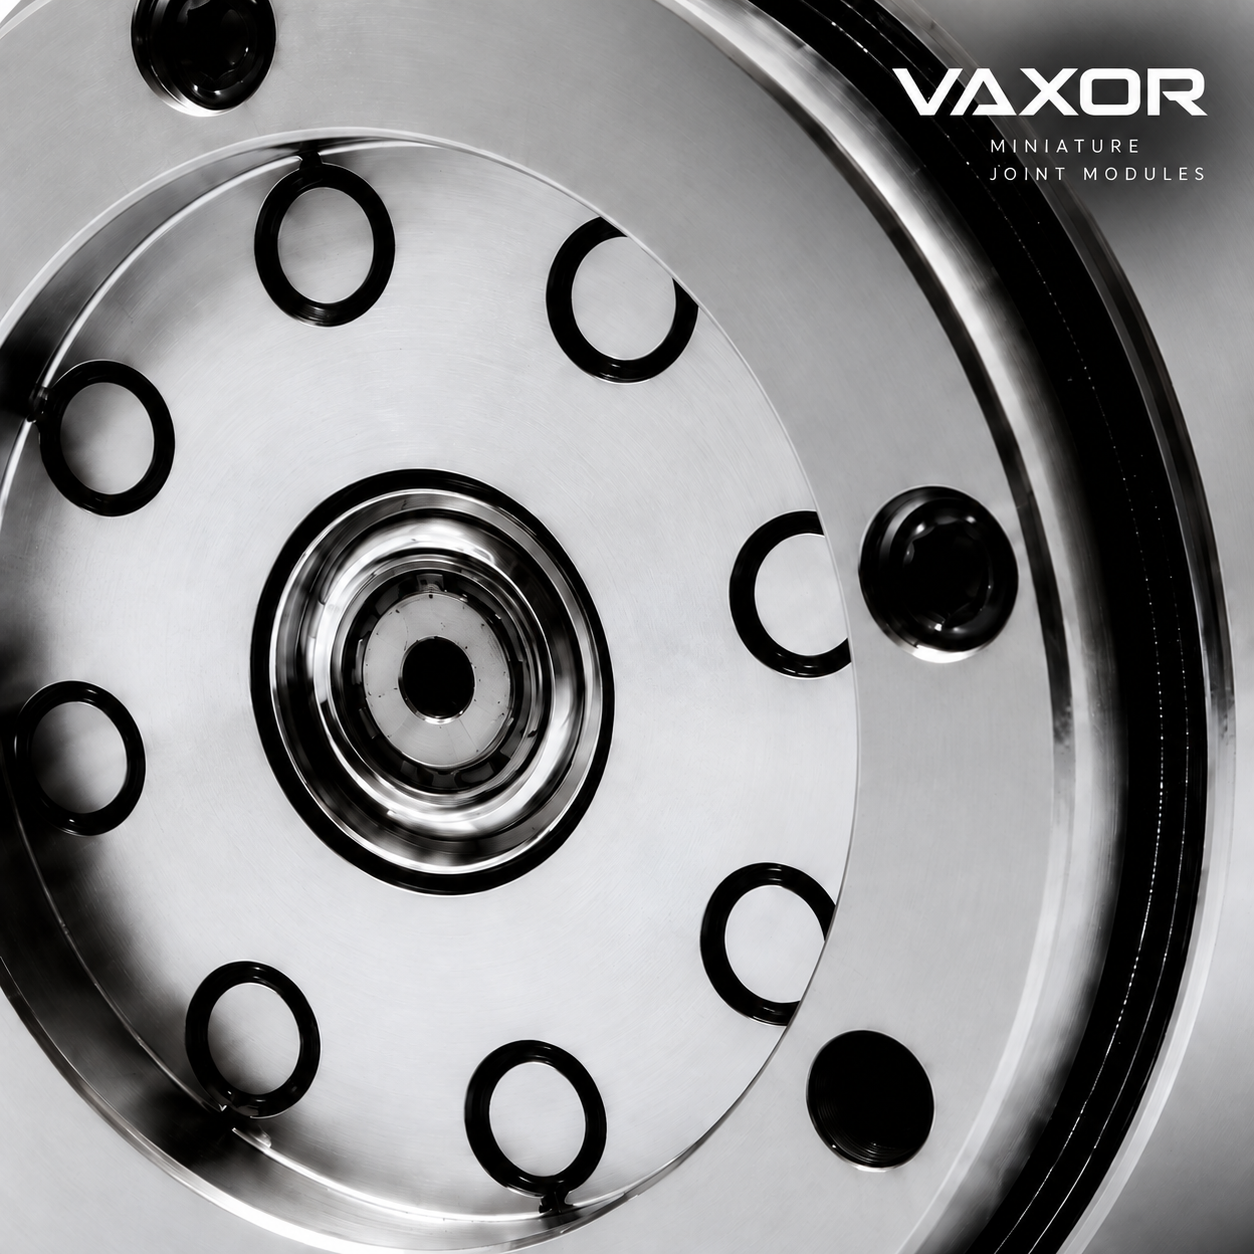
The Φ16mm Micro Joint Module (X16S/X16L) is built for precision micro-manipulation in highly integrated robotic systems. It weighs as little as 24.3g (S-version) or 26.1g (L-version), with continuous stalling torque above 7.1 mNm and maximum stalling torque above 16.5 mNm. It integrates gear reduction ratios of 30, 40, and 50, along with an absolute magnetic encoder and SPI communication for low-latency control response. Thermal management is built in via chassis temperature limits of 80°C, 115°C, or 145°C depending on power loss conditions.
The Φ20mm Micro Joint Module (X20S/X20L) targets medium-load precision actuation for bionic and automation applications. It delivers continuous stalling torque above 17.2 mNm and maximum stalling torque above 35.3 mNm, supports 12V/24V/48V operation, and offers gearbox ratios of 15, 30, and 50. At ratio 50, assembly-level stalling torque reaches up to 450 mNm. It uses a standardized FPC 7PIN interface to simplify integration into robotic limbs.
The Φ25mm Micro Joint Module (X25S-UZ/X25S-BZ) is designed for high-torque use in industrial and medical robotics. It uses the CAN FD protocol for robust communication and delivers continuous stalling torque up to 1150 mNm at ratio 50, with mechanical strength limits reaching 1800 mNm in initial cold-state torque. Backlash is reduced to 15 Arcmin.
The Φ30mm Micro Joint Module (X30S-UZ/X30S-BZ) is the premium module in the line, built for heavy-duty micro-robotic applications. It reaches continuous stalling torque up to 1500 mNm at ratio 50, gear efficiency up to 75% at ratio 30, total inertia of 30.4 gcm², and supports CAN FD integration for multi-joint robot network architectures.
Ultra-Micro Brushless & Coreless Motors
This line, the G04P/G05P/G06P series, is positioned for ultra-compact power delivery in precision instruments, with direct industry adaptation listed for medical micro-surgical robots, photonics (precision optical adjustments), and consumer electronics (miniature haptics and pumps).
These motors weigh between 1.7g and 3.75g and reach no-load speeds from 55,000 to 63,000 RPM, suited to micro-pumps and drones. They support chassis temperatures up to 145°C and terminal resistance as low as 1.6Ω, which improves electrical efficiency. The same phase imbalance control within 5% that defines the broader platform applies here as well, reducing production cost variance and improving reliability for high-cost, low-yield sub-6mm motor manufacturing.
Platform Compatibility and System Integration
For engineering teams integrating VAXOR-MOTOR modules into existing systems, platform compatibility covers 12V, 24V, and 48V DC bus systems. Communication is handled through SPI or CAN FD protocols, and hardware integration uses a standardized FPC 7PIN interface (0.5mm pitch) supporting VCC, GND, CS, SCK, MOSI, MISO, and CAL (calibration) lines. This combination of voltage flexibility and standardized interfacing is intended to reduce integration friction for system designers working across robotics, medical device, and industrial automation projects.
Demonstrated Applications
VAXOR-MOTOR’s technology has been applied across several documented use cases. Robotic dexterous hands have used X16 and X20 modules to achieve high-integration mechanical motion control that supports human-like finger dexterity. Industrial automation systems have integrated Φ30mm modules into precision transmission systems, achieving 75% gear efficiency and backlash as low as 15 Arcmin. Micro pump systems, relevant to both medical and consumer applications, have used G05P ultra-micro motors running at 55,000 RPM to drive fluid transmission with low cost and high power density. Photon optics applications have used ultra-micro brushless motors for precision positioning in optical instruments, relying on the same sub-5% phase imbalance for stable performance.
Industry Coverage and Engagement Model
VAXOR-MOTOR’s business coverage spans robotics (including bionic systems and dexterous hands), medical devices, industrial automation, consumer electronics, aerospace (micro drones), fluid transmission, and photonics. Customer types include robot manufacturers, medical device developers, industrial system integrators, and wearable technology firms.
The company’s pricing approach is product-based, built around standardized modules across the X16, X20, X25, and X30 series. Delivery is handled through hardware integration using standardized FPC 7PIN interfaces or CAN FD/SPI communication protocols, with after-sales support covering technical inquiries and discussions about product specifications and operational parameter ranges.
Summary
For engineering teams developing medical robots or related precision systems, the core requirement is consistent: compact actuators that deliver predictable torque, low backlash, and accurate position feedback without excessive weight or power draw. VAXOR-MOTOR’s integration of axial flux motors, cycloidal gear reducers, and non-contact magnetic encoders, backed by documented technical metrics across the X16 through X30 module series and the G04P/G05P/G06P motor series, is built specifically around that requirement. Teams evaluating actuation partners for medical, industrial, or robotic applications can assess fit directly against the torque, weight, efficiency, and interface specifications documented across VAXOR-MOTOR’s product matrix.
Related products
-
Quick View
MG1 Mechanical Seal MG12 Mechanical Seal MG13 Mechanical Seal
Contact UsThe MG1 series is a very classic lightweight universal product in our mechanical seal industry. Its auxiliary seal is mainly made of rubber bellows
-
Quick View

DS-RF Selective Formaldehyde module HCHO Module
Contact UsDS-RF selective formaldehyde module can detect HCHO, VOC, TVOC, t & RH at the same time.
-
Quick View
High-Volume Consumer Electronics PCBA
Contact UsConsumer Electronics PCBAs are circuit board assemblies designed for a wide range of everyday electronic devices, offering compact design, reliable performance, and cost-effective manufacturing.
-
Quick View

4.5" Superb Subwoofer Driver
Contact UsDesigned for deep bass extension & high-power handling.400W Peak Power: Robust output for home theater/car audio.Dual Spider Design: Enhances linearity, reduces distortion.
Reviews
There are no reviews yet.