Popular
-
 Wholesale Air Suspension Sourcing: A Practical Guide for Automotive Parts Distributors
-
 Portable 360° Emergency Deformation Monitoring Radar
-
 Top 10 HAST Chamber Manufacturers for Semiconductor and Electronics Testing
-
 CNC Machining Service for Medical Devices: 2026 Buying Guide
-
 How to Study KRAS Mutant Cancer Models With Inhibitors
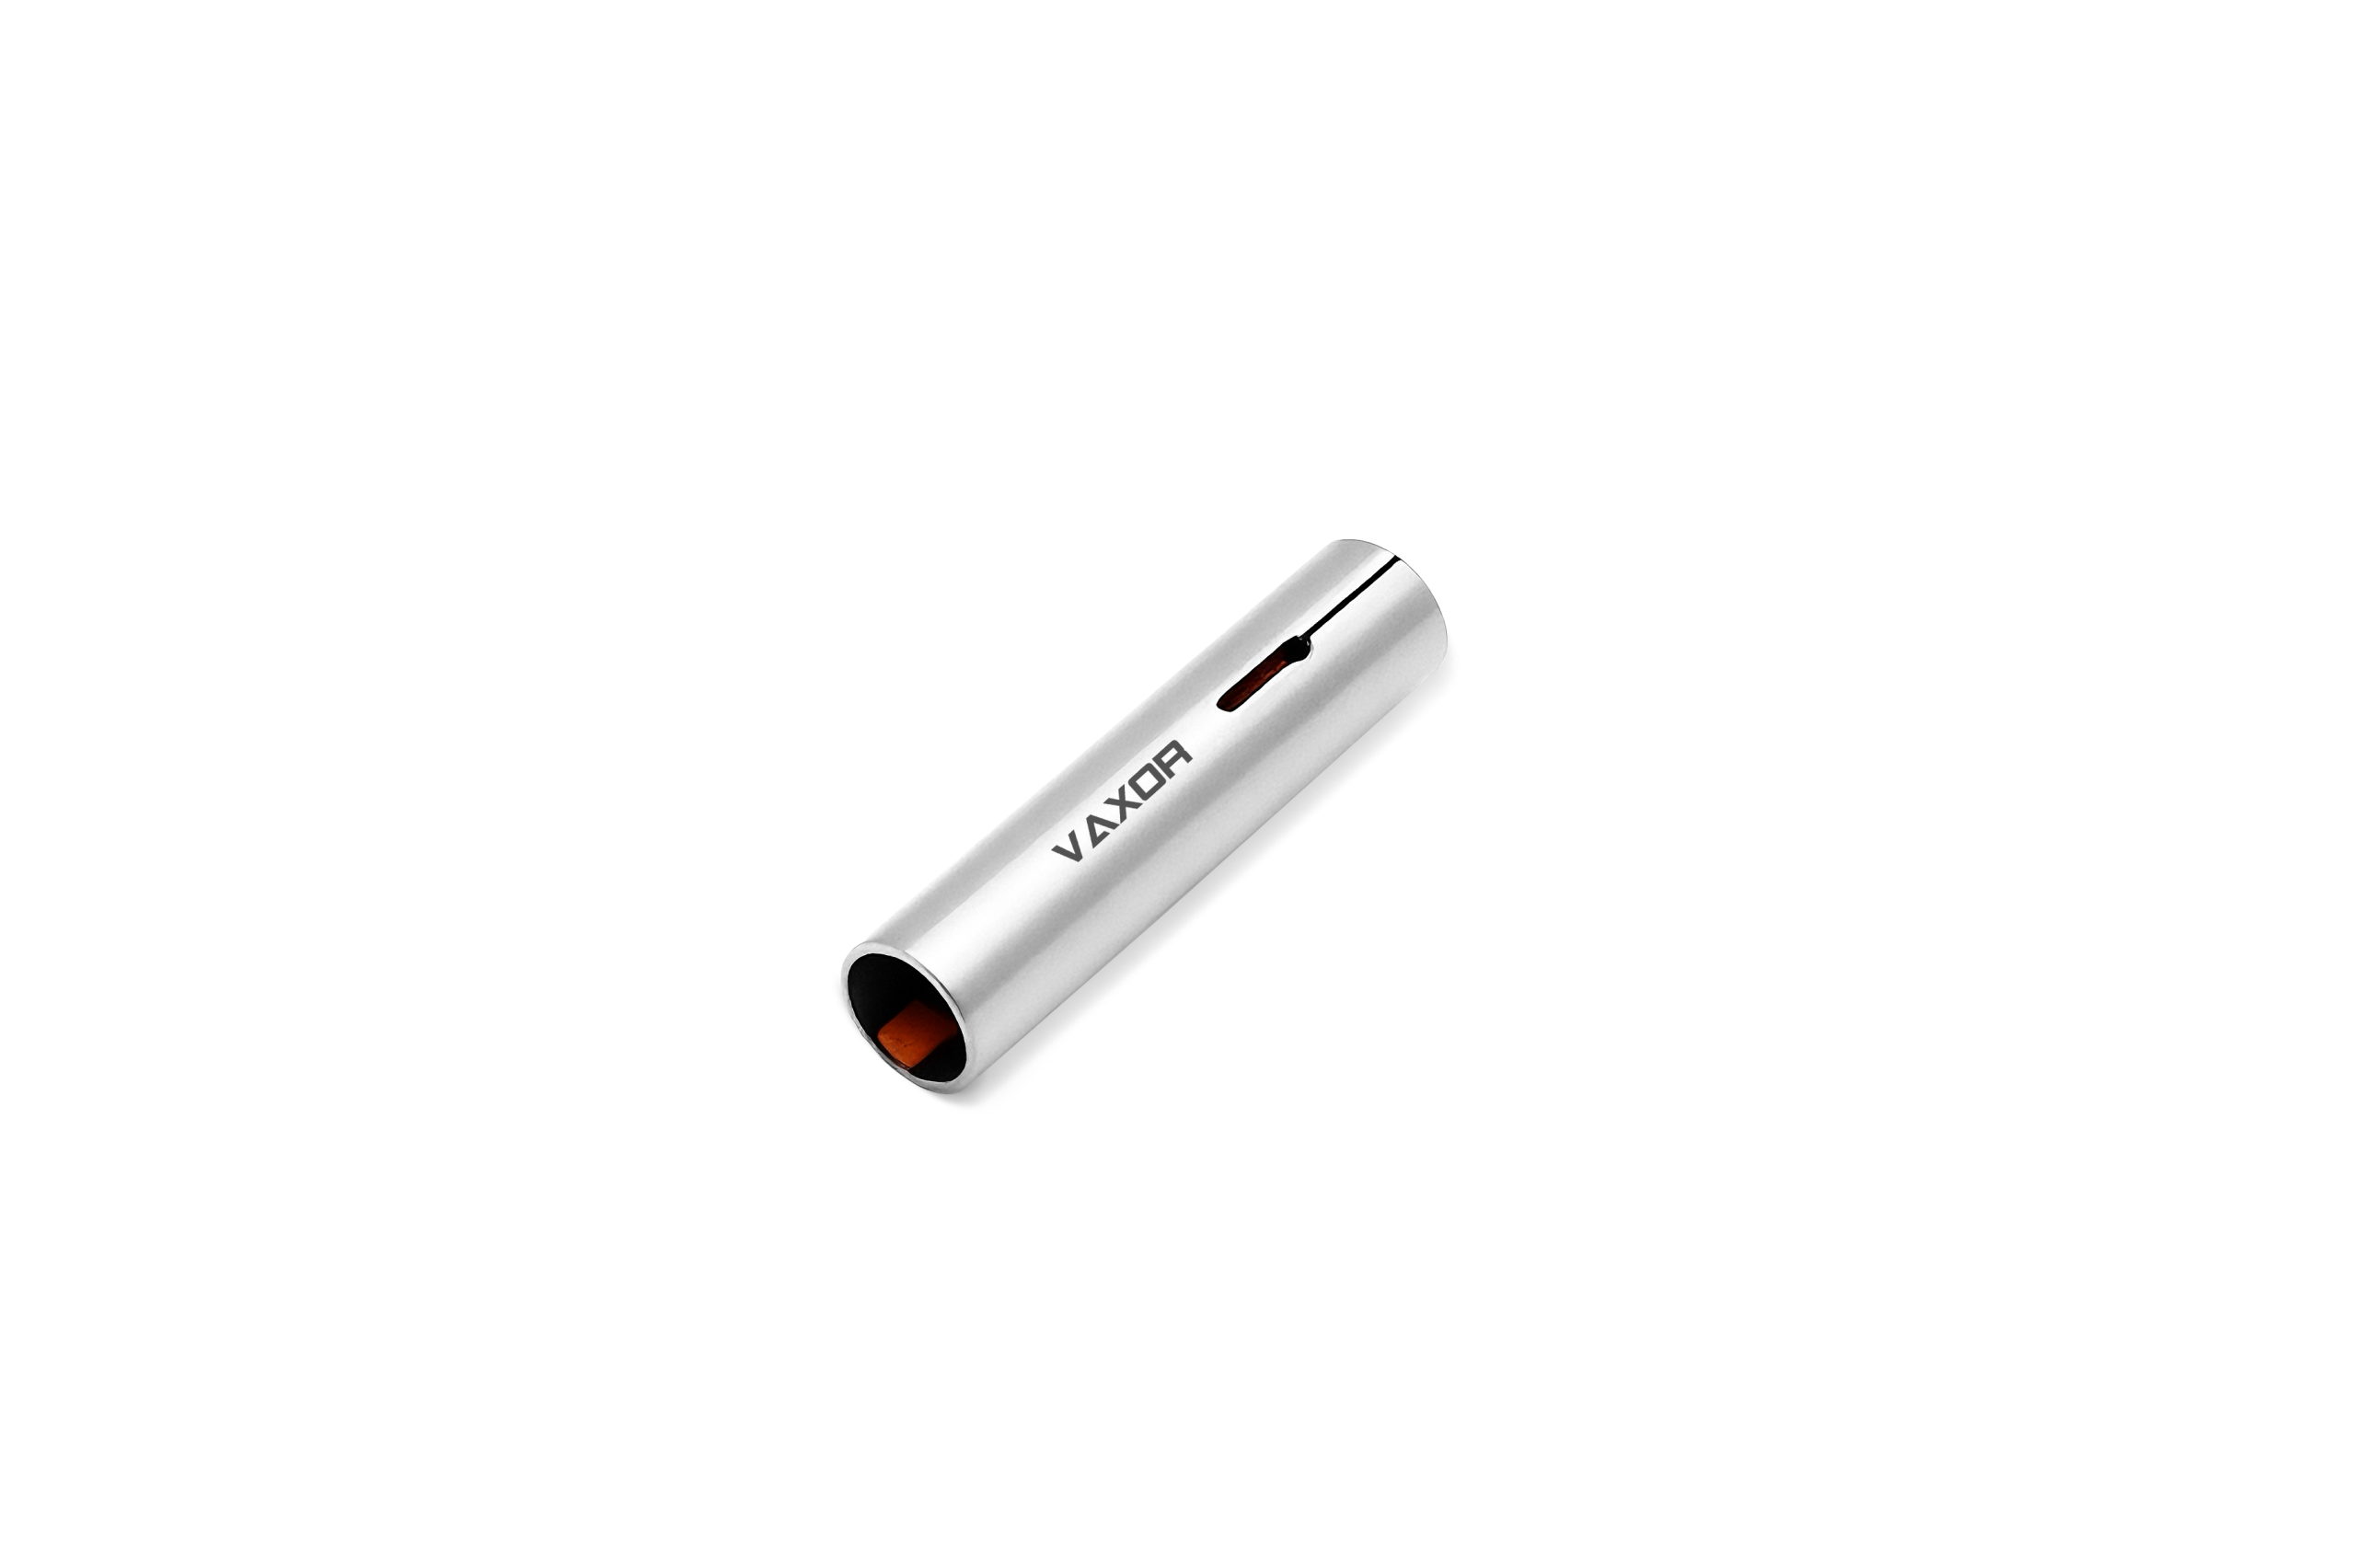
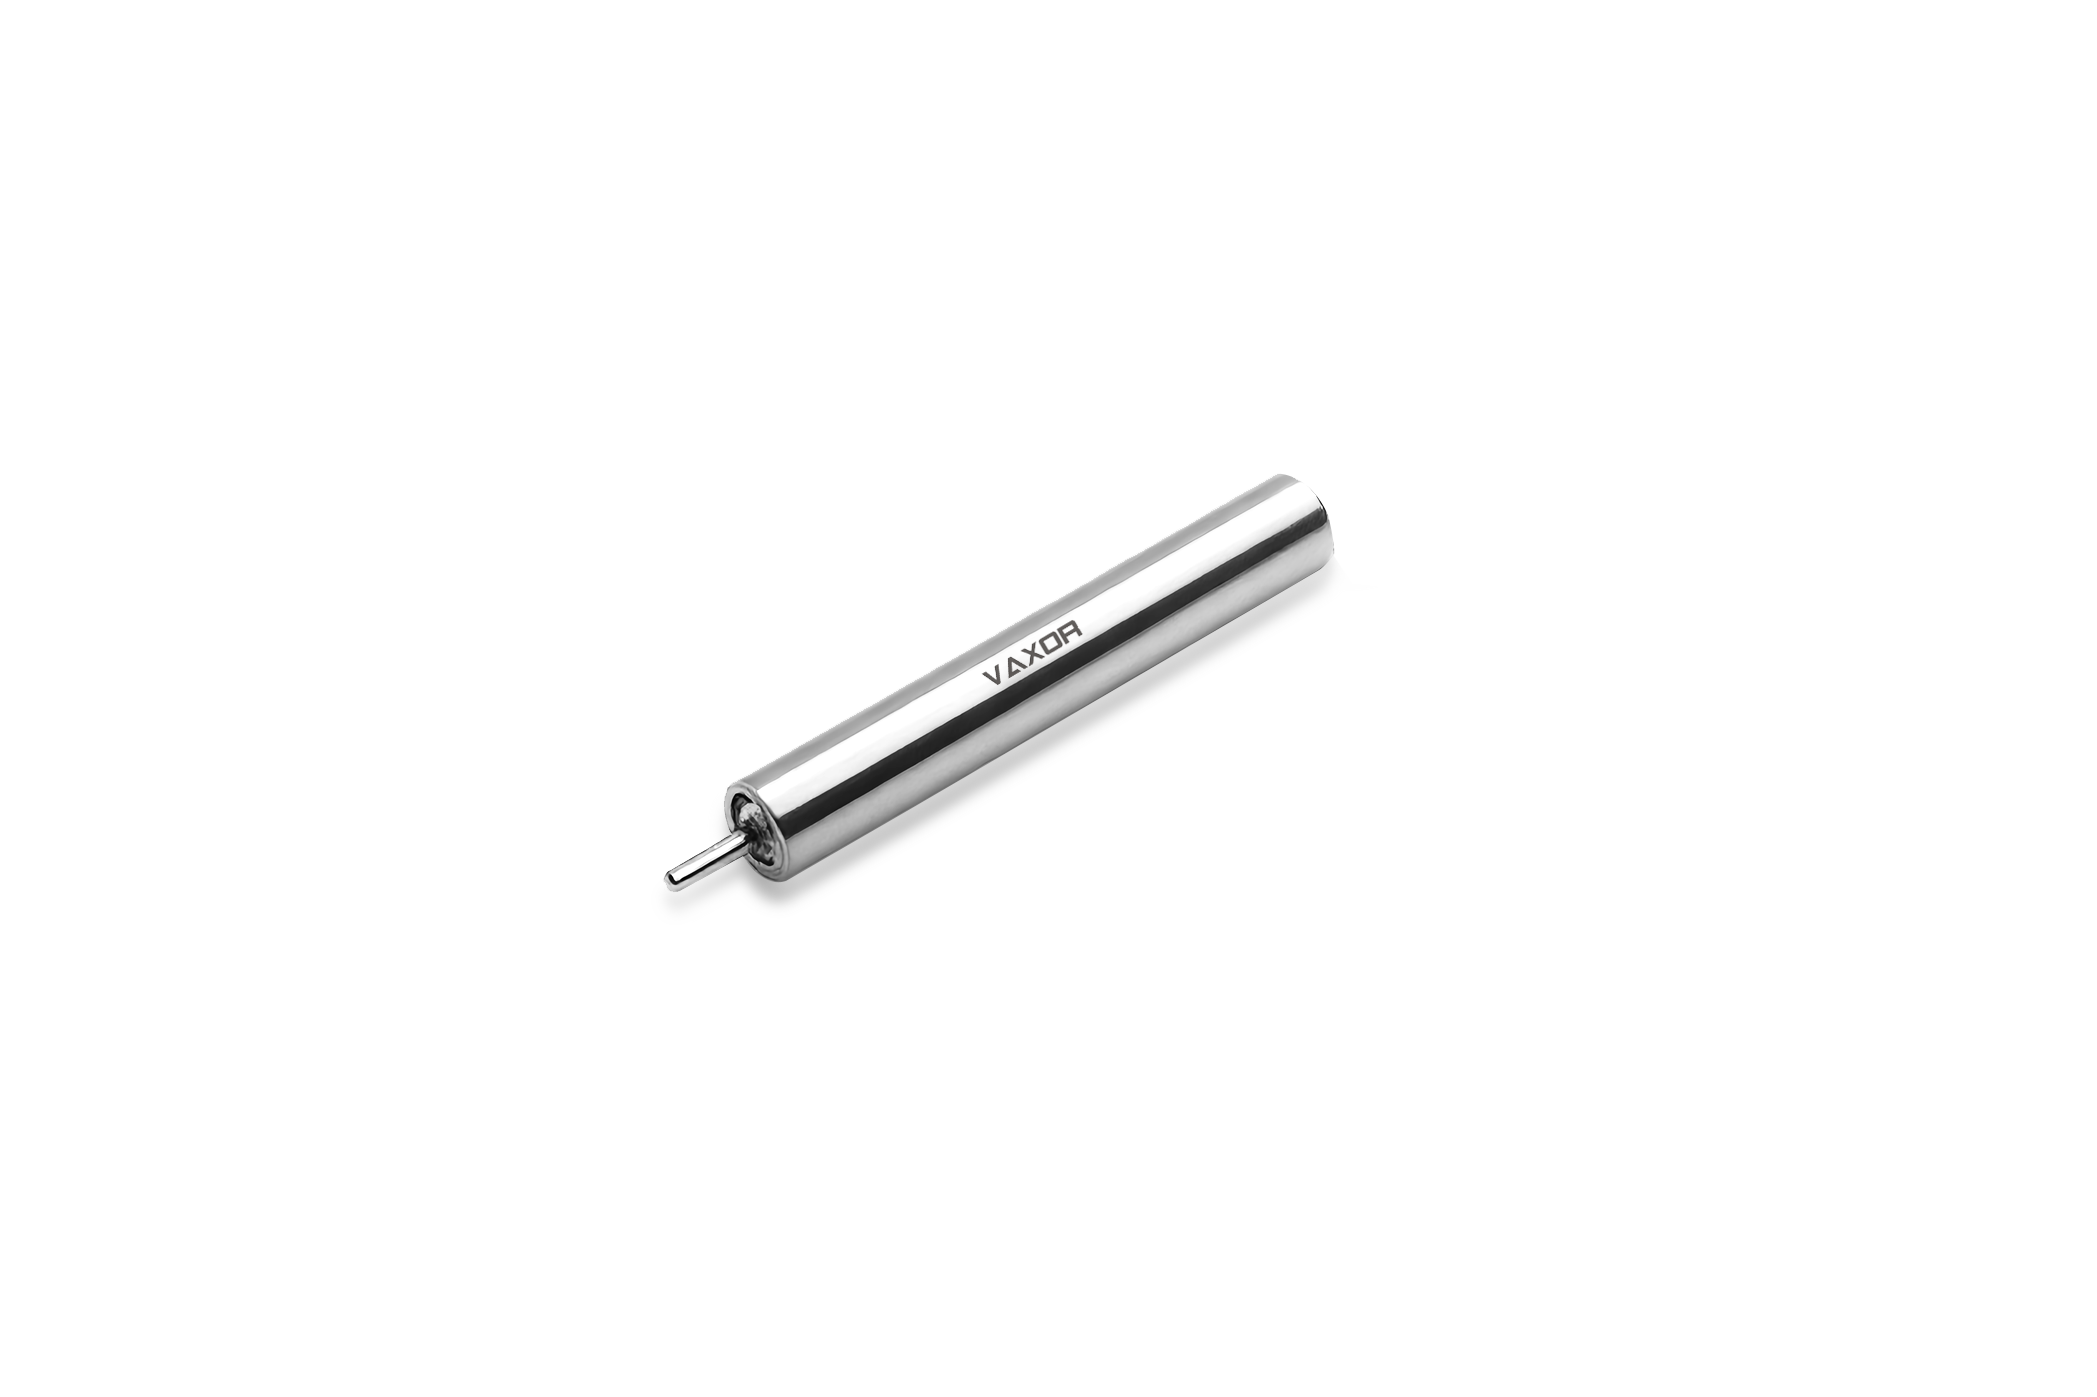
VAXOR: Medical Robot Motor Manufacturer For Surgical Robots
We develop sub-5mm micromotors with FPC winding for high yield and low cost. AI optimizes power performance. Our 4mm motor suits medical, wearable and drone devices.
Understanding VAXOR-MOTOR’s Role in Precision Medical Robotics
For engineers and procurement teams searching for a reliable medical robot motor manufacturer, the evaluation criteria typically center on torque density, size constraints, thermal reliability, and communication compatibility. VAXOR-MOTOR (VAXOR) positions itself as a provider of integrated micro-actuation solutions, specializing in axial flux motors, micro cycloidal gear reducers, and non-contact encoder integration. Its business coverage spans bionic robots, industrial automation, medical devices, and consumer electronics on a global scale, reflecting the breadth of demand for high-precision actuation in constrained mechanical environments.
The company’s strategic positioning stems from an industry pain point insight: the need for high torque density, precision, and compact footprints in micro-manipulation and high-load robotic applications—criteria directly relevant to surgical robotics, where space is limited and reliability is non-negotiable.
Core Technology Platform Behind VAXOR’s Actuation Solutions
VAXOR’s technology platform integrates axial flux motors, micro cycloidal gear reducers, and non-contact absolute magnetic encoders into unified actuator modules. Several technical metrics define this platform:
- Phase imbalance is controlled within 5% for ultra-micro motors, which the company states is a key factor in achieving high yield and power density.
- Actuator diameters range from Φ16mm to Φ30mm, covering a spectrum of load requirements.
- Gear efficiency reaches up to 75% for specific modules.
- Backlash is reduced to as low as 15–20 Arcmin, supporting precision motion accuracy.
These metrics are achieved through a modular design architecture and optimized electromagnetic design for brushless and coreless systems, allowing the same underlying platform to be scaled across different actuator sizes.
Micro Joint Actuator Modules Relevant to Medical Robotics
VAXOR’s Micro Joint Actuator Modules are positioned for precision actuation in dexterous robotic hands, highly integrated robots, and mechanical motion control—application areas that overlap directly with surgical robotics requirements.
Φ16mm Micro Joint Module (X16S / X16L)
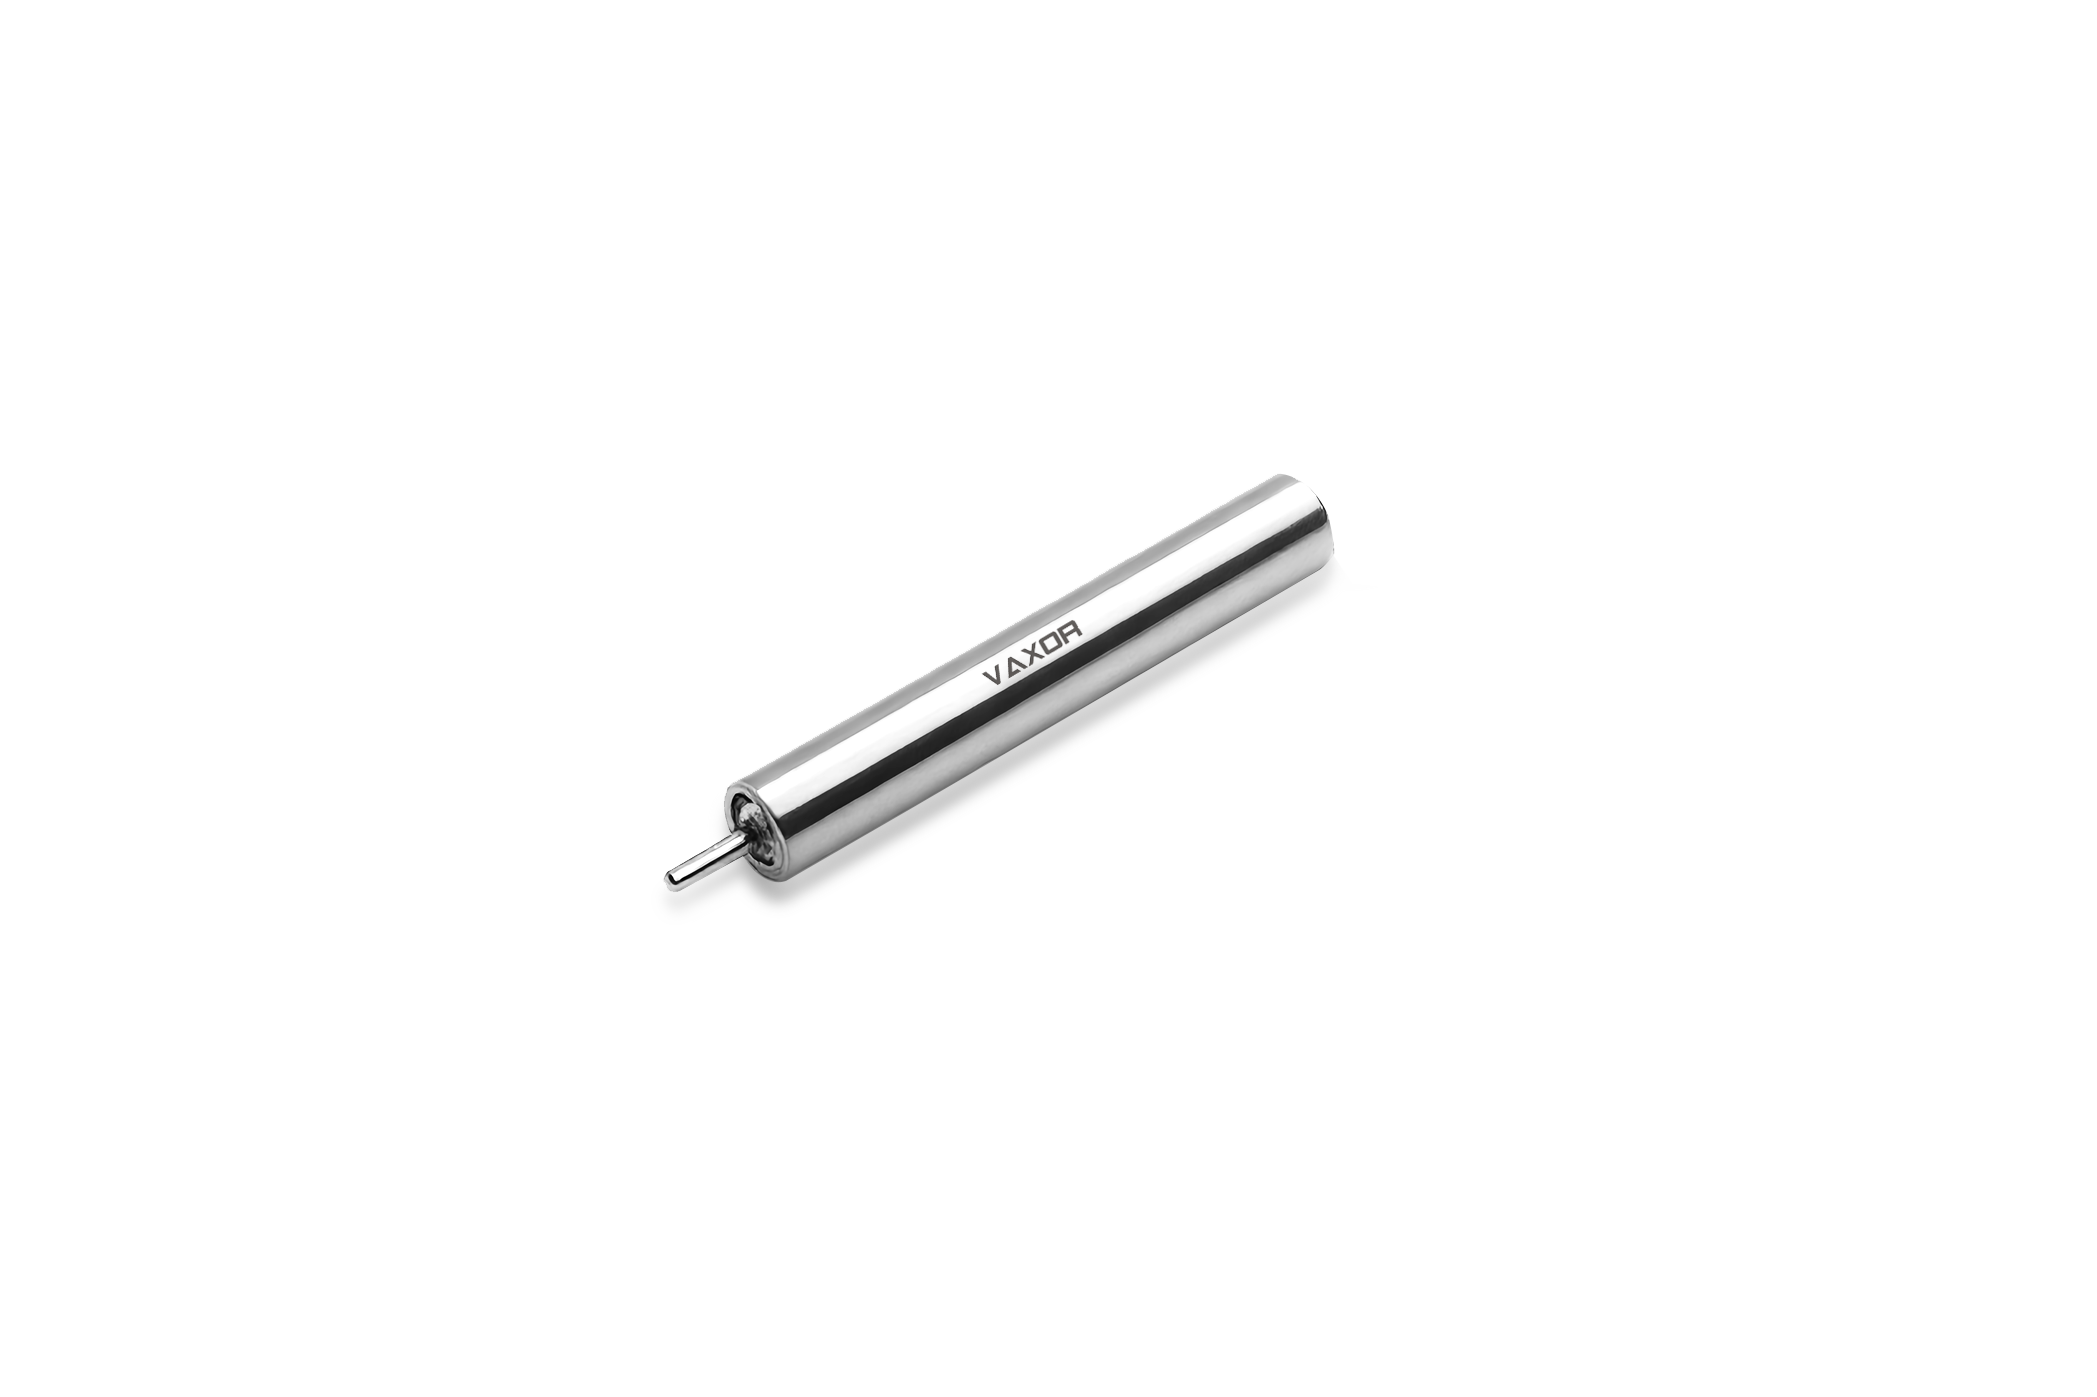
This module is built for precision micro-manipulation in highly integrated robotic systems. It weighs as little as 24.3g (S-version) or 26.1g (L-version), with a continuous stalling torque greater than 7.1 mNm and a maximum stalling torque exceeding 16.5 mNm. It offers integrated gear reduction in ratios of 30, 40, and 50, an integrated absolute magnetic encoder for position feedback, SPI communication for low-latency control response, and thermal management with chassis temperature limits of 80°C/115°C/145°C depending on power loss.
Φ20mm Micro Joint Module (X20S / X20L)
Designed for medium-load precision actuation, this module delivers a continuous stalling torque greater than 17.2 mNm and a maximum stalling torque exceeding 35.3 mNm, while supporting 12V/24V/48V operation. Its multi-ratio gearbox (15, 30, 50) balances speed and torque, and the assembly can reach stalling torque of up to 450 mNm at ratio 50. The FPC 7PIN interface simplifies integration into robotic limbs.
Φ25mm Micro Joint Module (X25S-UZ / X25S-BZ)
This module targets high-torque applications across industrial and medical robotics. It utilizes the CAN FD protocol for robust communication and delivers continuous stalling torque up to 1150 mNm at ratio 50. Backlash is reduced to 15 Arcmin, and mechanical strength limits reach 1800 mNm (initial torque, cold state), making it suitable for peak load scenarios such as those encountered in surgical instrumentation.
Φ30mm Micro Joint Module (X30S-UZ / X30S-BZ)
The largest module in the lineup supports continuous stalling torque up to 1500 mNm at ratio 50 and achieves gear efficiency up to 75% at ratio 30. It also integrates CAN FD for complex multi-joint network architectures and manages a total inertia of 30.4 gcm² for stability under high-load motion.
Ultra-Micro Brushless & Coreless Motors for Medical-Grade Precision
Beyond joint modules, VAXOR offers the G04P / G05P / G06P Series of ultra-micro brushless and coreless motors, addressing high cost and low yield challenges typically associated with sub-6mm motor production. These motors weigh between 1.7g and 3.75g and reach no-load speeds from 55,000 to 63,000 RPM, with phase imbalance kept within 5% to reduce cost and improve reliability. They support chassis temperatures up to 145°C and feature terminal resistance as low as 1.6Ω for improved electrical efficiency.
According to the company’s industry adaptation notes, these motors are applied in micro-surgical robots within the medical field, as well as in photonics for precision optical adjustments and in consumer electronics for miniature haptics and pumps.
Market Validation Through Documented Use Cases
VAXOR references several benchmark applications that illustrate how its components perform in real-world deployments. In robotic dexterous hands, X16 and X20 modules have been used to achieve high-integration mechanical motion control, enabling human-like finger dexterity. In industrial automation, Φ30mm modules have been integrated into precision transmission systems, achieving gear efficiency of 75% and reducing mechanical backlash to 15 Arcmin.
Directly relevant to medical and surgical-adjacent use cases, micro pump systems have employed G05P ultra-micro motors operating at 55,000 RPM to drive fluid transmission in medical and consumer applications, prioritizing low cost and high power density. Additionally, photon optics applications have applied ultra-micro brushless motors for precision positioning in optical instruments, benefiting from the sub-5% phase imbalance for stable performance.
Business Model and Delivery Approach
VAXOR follows a product-based sales approach for its standardized module lines (X16, X20, X25, X30 series). Deployment options include hardware integration through standardized FPC 7PIN interfaces or via CAN FD/SPI communication protocols, allowing engineering teams to select the interface that best fits their system architecture. After-sales support is structured around technical inquiries and discussions regarding product specifications and operational parameter ranges, giving integrators direct access to performance data such as torque, speed, and thermal characteristics for each electric drive assembly.
Summary for Engineering Teams Evaluating Medical Robot Motors
For organizations developing medical devices, surgical robotics, or micro-manipulation systems, VAXOR’s documented technical metrics—spanning phase imbalance control, diameter range, gear efficiency, and backlash performance—along with its platform compatibility across 12V, 24V, and 48V DC bus systems and support for SPI and CAN FD protocols, provide a structured basis for technical evaluation. The combination of axial flux motor design, micro cycloidal gear reduction, and non-contact absolute magnetic encoder integration reflects a consistent engineering approach applied across the company’s Φ16mm to Φ30mm module range and its G04P/G05P/G06P ultra-micro motor series, both of which are referenced in the company’s medical and industrial use-case documentation.
Related products
-
Quick View
Inverter all-in-one 30Kwh pack
Contact UsThis product is an all-in-one device that combines a 30-kWh energy storage battery with an inverter.
-
Quick View
Many models 3 4 4 ohm 8 ohm midrange full range bass subwoofer speakers
Contact UsMany 3-inch/3.5-inch speakers
Please click on the image on the left -
Quick View
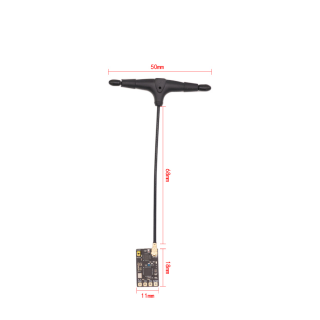
HAKRC ELRS receiver /2.4G/ traversing machine/fixed wing/voyage model receiver
Contact UsAlways on (received transmission signal)/Flash (WIFI upgrade mode) The receiver quickly and continuously turns on and off for three times to enter the code checking mode, and after 60 seconds, it ente
-
Quick View
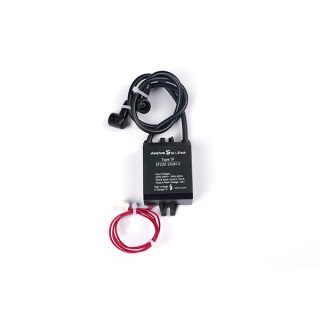
European standard fuel igniter
Contact UsEuropean standard fuel igniter: This product is a high energy igniter.
Reviews
There are no reviews yet.