Popular
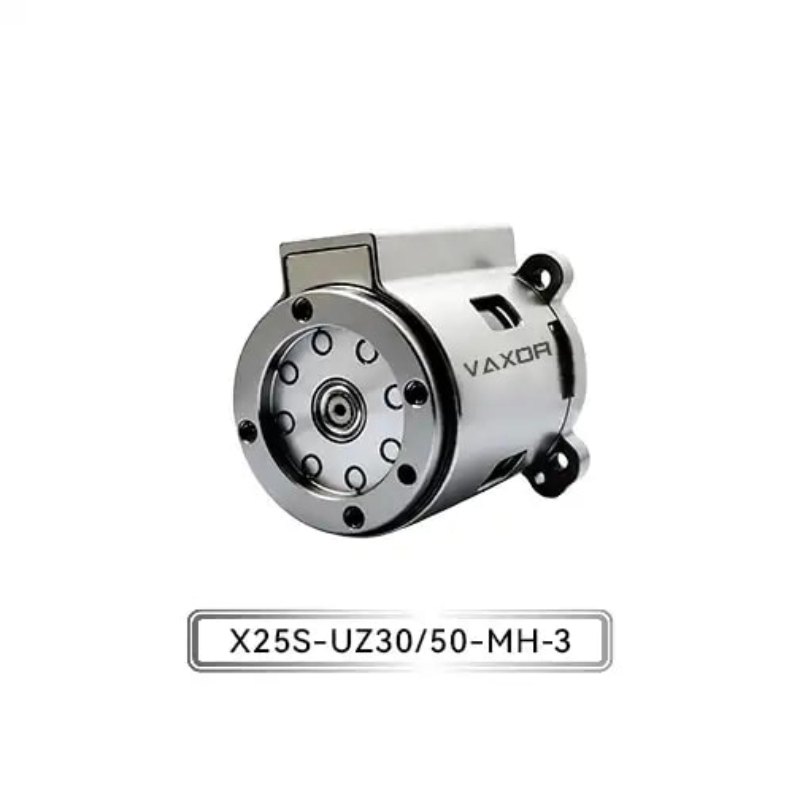
Φ25mm Micro Joint Actuator – Compact High-Torque Actuator for Robotics
A compact Φ25mm actuator integrating an axial-flux motor, cycloidal reducer, and absolute encoder.
1. Product Introduction
Designed for compact robotic systems and precision motion applications, the Φ25mm Micro Joint Actuator combines an axial-flux motor, a miniature cycloidal reducer, and a non-contact absolute magnetic encoder in one integrated drive unit. With a compact 25 mm form factor, it balances torque output, motion precision, and cost efficiency for applications where installation space and weight are critical.
Operating at 12–18 V, this micro joint actuator supports gear ratios of 30:1 and 50:1, with continuous torque of up to 1150 mNm and initial torque of up to 1800 mNm. CAN FD communication enables integration with compatible control systems, making it suitable for collaborative robots, biomimetic joints, and other compact intelligent machines.
Developed by VAXOR, the actuator reflects an engineering approach that combines motor design, precision manufacturing, structural optimization, and robotics control to support the development of smaller and more capable motion systems.
2. Key Product Advantages
2.1 Compact Φ25mm Structure
The miniature form factor helps reduce installation space in robotic joints and other space-constrained equipment. Its integrated architecture can simplify the arrangement of motor and transmission components within compact mechanisms.
2.2 Axial-Flux Motor Technology
The axial-flux motor design supports a compact drive architecture with an emphasis on torque density. It is suitable for applications that require meaningful torque output within limited installation dimensions.
2.3 Miniature Cycloidal Reduction Mechanism
The integrated cycloidal reducer provides gear reduction in a compact package. Available gear ratios of 30 and 50 allow engineers to select a configuration according to the torque and speed requirements of the target mechanism.
2.4 High Torque Output
The actuator delivers continuous torque of up to 1150 mNm and initial torque of up to 1800 mNm. Actual performance depends on the selected configuration and operating conditions, so application-specific validation is recommended.
2.5 Non-Contact Absolute Magnetic Encoder
The absolute magnetic encoder supports position feedback without a contacting sensing mechanism. It is designed for integration into precision motion-control systems where position information is important for coordinated joint movement.
2.6 CAN FD Communication
CAN FD communication supports connection to compatible controllers and control networks. System integrators should confirm protocol implementation, message definitions, connector pinout, and controller compatibility before deployment.
2.7 Lightweight Construction
With a listed weight of 93–103 g, the actuator is suited to compact robotic assemblies where component mass affects joint design and overall system weight.
3. Technical Specifications
| Parameter | Specification |
|---|---|
| Product Name | Φ25mm Micro Joint Actuator |
| Model | X25S-UZ/BZ30/50-MH-3 |
| Actuator Diameter | Φ25 mm |
| Operating Voltage | 12–18 V |
| Gear Ratio | 30 / 50 |
| Continuous Torque | Up to 1150 mNm |
| Initial Torque | Up to 1800 mNm |
| Encoder Type | Absolute Magnetic Encoder |
| Communication Interface | CAN FD |
| Weight | 93–103 g |
| Motor Technology | Axial-Flux Motor |
| Reduction Mechanism | Miniature Cycloidal Reducer |
Note: The torque figures are stated maximum values. Rated speed, output speed, peak-torque duration, current consumption, encoder resolution, control modes, dimensions beyond the nominal diameter, and environmental ratings should be confirmed against the technical datasheet for the selected configuration.
4. Typical Applications
Collaborative Robots
The compact structure and integrated drive components make the actuator a potential solution for collaborative robot joints and compact robotic mechanisms. Final selection should consider joint torque, speed, duty cycle, and thermal requirements.
Biomimetic Robotics
For biomimetic joints that imitate natural movement, the actuator offers an integrated motor, reduction mechanism, and position-feedback architecture to support compact joint design.
Compact Robotic Manipulators
The small diameter and lightweight construction can help engineers develop robotic arms and mechanisms with limited installation space.
Precision Instruments
The integrated absolute magnetic encoder and communication interface may support motion subsystems in precision equipment, subject to the accuracy and control requirements of the application.
Intelligent Equipment and Research Prototypes
The actuator can be evaluated for compact motion modules, experimental robotic platforms, and other intelligent equipment requiring integrated drive components.
5. Model Selection and Configuration
The X25S-UZ/BZ30/50-MH-3 model is listed with gear ratios of 30 and 50. Selection should be based on the operating requirements of the complete motion system.
-
Gear ratio: Choose the appropriate ratio according to the required output torque and speed.
-
Supply voltage: Confirm that the system power supply remains within the specified 12–18 V range.
-
Torque requirements: Evaluate continuous operating torque separately from initial or transient torque.
-
Control integration: Check CAN FD compatibility with the host controller and software architecture.
-
Mechanical integration: Verify mounting dimensions, output interface, cable routing, and installation clearance with the supplier before finalizing the design.
For project-based applications, provide the intended use, target output speed, required torque, available installation space, supply voltage, and control-system details to help determine suitability.
6. Why Choose VAXOR Micro Drive Solutions?
VAXOR was founded in 2024 and is headquartered in Suzhou, China. The company develops micro joint actuators and ultra-micro coreless motors for robotics, medical devices, precision instruments, and intelligent equipment.
Its technical approach integrates axial-flux motor technology, PCB/FPCB winding, electromagnetic optimization, and miniature reduction mechanisms to address the core demands of compact drive systems: small size, high performance, and scalable production.
Key capabilities include:
-
Multidisciplinary R&D: Expertise spanning motor design, precision manufacturing, structural design, and robotics control.
-
Engineering implementation: Experience across prototype validation, pilot production, and batch-delivery processes.
-
International technical background: Team members with academic and industrial R&D experience in China and overseas.
-
Application-oriented development: Micro-drive products designed for integration into compact robotics and intelligent equipment.
-
Development and production focus: An emphasis on translating motor technology and engineering development into practical drive solutions.
VAXOR products have been supplied or sampled to robotics companies, technology enterprises, and research institutions worldwide. Availability, lead time, customization scope, and production quantities should be confirmed for each project.
7. Ordering and Technical Inquiry
To request a quotation or evaluate the Φ25mm Micro Joint Actuator for your project, please provide the following information where available:
-
Required model and gear ratio.
-
Estimated annual or project quantity.
-
Target continuous torque and output speed.
-
Supply voltage and power constraints.
-
Controller type and CAN FD integration requirements.
-
Mechanical drawings or installation-space limitations.
-
Prototype or mass-production schedule.
The supplier can then review the application requirements and confirm the appropriate configuration, technical documentation, pricing, and delivery schedule.
8. Frequently Asked Questions
Q1: What is the operating voltage of this actuator?
The specified operating voltage is 12–18 V. Confirm the power-supply requirements for the intended configuration before integration.
Q2: What gear ratios are available?
The listed gear ratios are 30 and 50. The suitable option depends on the required output torque and speed.
Q3: What torque can the actuator provide?
The listed continuous torque is up to 1150 mNm, while the initial torque is up to 1800 mNm. These maximum values should not be interpreted as interchangeable operating ratings. Confirm the applicable torque limits and duty conditions with the supplier.
Q4: What encoder does the actuator use?
It uses an absolute magnetic encoder with a non-contact sensing design. Confirm encoder resolution and interface details for your control system.
Q5: Which communication interface is supported?
The listed communication interface is CAN FD. Protocol details and controller compatibility should be checked before system integration.
Q6: Is this actuator suitable for collaborative robots?
It is designed with collaborative robot joints and biomimetic joints among its target applications. Suitability for a particular robot depends on torque, speed, thermal behavior, mechanical fit, control requirements, and duty cycle.
Q7: How can I obtain a quotation?
Contact VAXOR with your target application, required gear ratio, quantity, operating requirements, and project timeline to request a configuration review and quotation.
9. Request a Quote
For compact robotic joints, biomimetic mechanisms, and precision motion projects, the Φ25mm Micro Joint Actuator offers an integrated drive architecture combining an axial-flux motor, miniature cycloidal reducer, and absolute magnetic encoder.
Contact VAXOR to discuss technical requirements, confirm configuration details, and evaluate the actuator for your next motion-control project.
Related products
-
Quick View
12Kg Medium Torque Brushless Electric screwdriver Trigger start type
Contact UsBrushless DC voltage automatic medium torque electric screwdriver series
Model: GW-B6212LF
Torque: 2~12Kgf.cm
Free Speed: HI 2000 / LO 1500 r.p.m -
Quick View
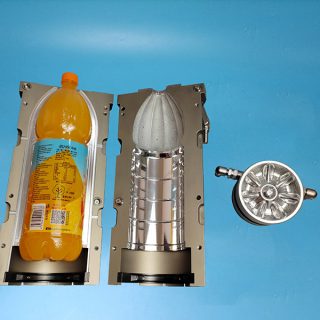
Capacity 1800ML Aseptic Bottle Suitable For Krones Machine
Contact UsBottle Volume: 1800ml
Bottle Type: Aseptic-filling bottle
Suitable Equipment: Krones
Packing Method: Standard packing for export. -
Quick View
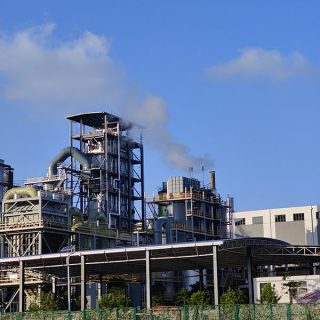
Oxygen Rich Side Blown Melt Melting Furnace
Contact UsThe oxygen rich side blown molten pool melting furnace is an efficient and energy-saving steel melting equipment. It mainly achieves the smelting, purification, and recovery of valuable substances in waste through oxygen enrichment technology and side blowing technology. Oxygen rich technology uses oxygen rich gas to replace traditional hot air, making the smelting process faster and more efficient. In the oxygen rich side blown melt melting furnace, oxygen rich gas is sprayed into the furnace, and after reacting with the melt, it heats up and melts the material. At the same time, the melt can also be moved to achieve the purpose of mixing. Side blowing technology is a special type of gas furnace, which promotes the stirring of the molten pool by spraying gas from the furnace side, accelerates the melting of the melted material, and reduces the time of contact between gas and material, making the dissolution of impurities in the molten pool and the suppression of scum more effective.
Reviews
There are no reviews yet.